ABB Robot Web Services
The ABB robot (Robot Web Services) source reads an IRC5 or OmniCore controller. A connection on this source is a robot device. Its panel, pose figure, roll-up and managed tags are on the Robots page. This page covers the connection.
Connection
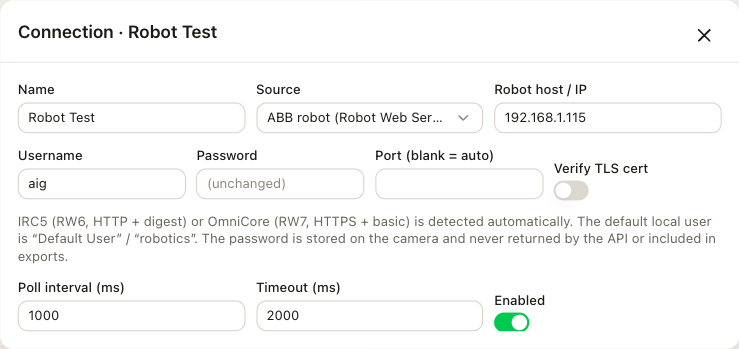
Choose Add connection and pick ABB Robot under Robots. The fields that every source shares are on the Connections page.
| Field | Description |
|---|---|
| Robot host / IP | The address of the robot controller. |
| Username, Password | The factory default is Default User with the password robotics. The camera stores the password and never returns it in the interface or in exports. |
| Port (blank = auto) | Leave it blank. The camera tries HTTP and then HTTPS on the standard ports. |
| Verify TLS cert | OmniCore controllers ship with a self-signed certificate, so verification is off by default. With verification on, a stock OmniCore fails to connect. |
The camera detects an IRC5 with RobotWare 6 over HTTP and an OmniCore with RobotWare 7 over HTTPS. Test connection connects once with the settings in the form and reports the result before you save.
Catalog
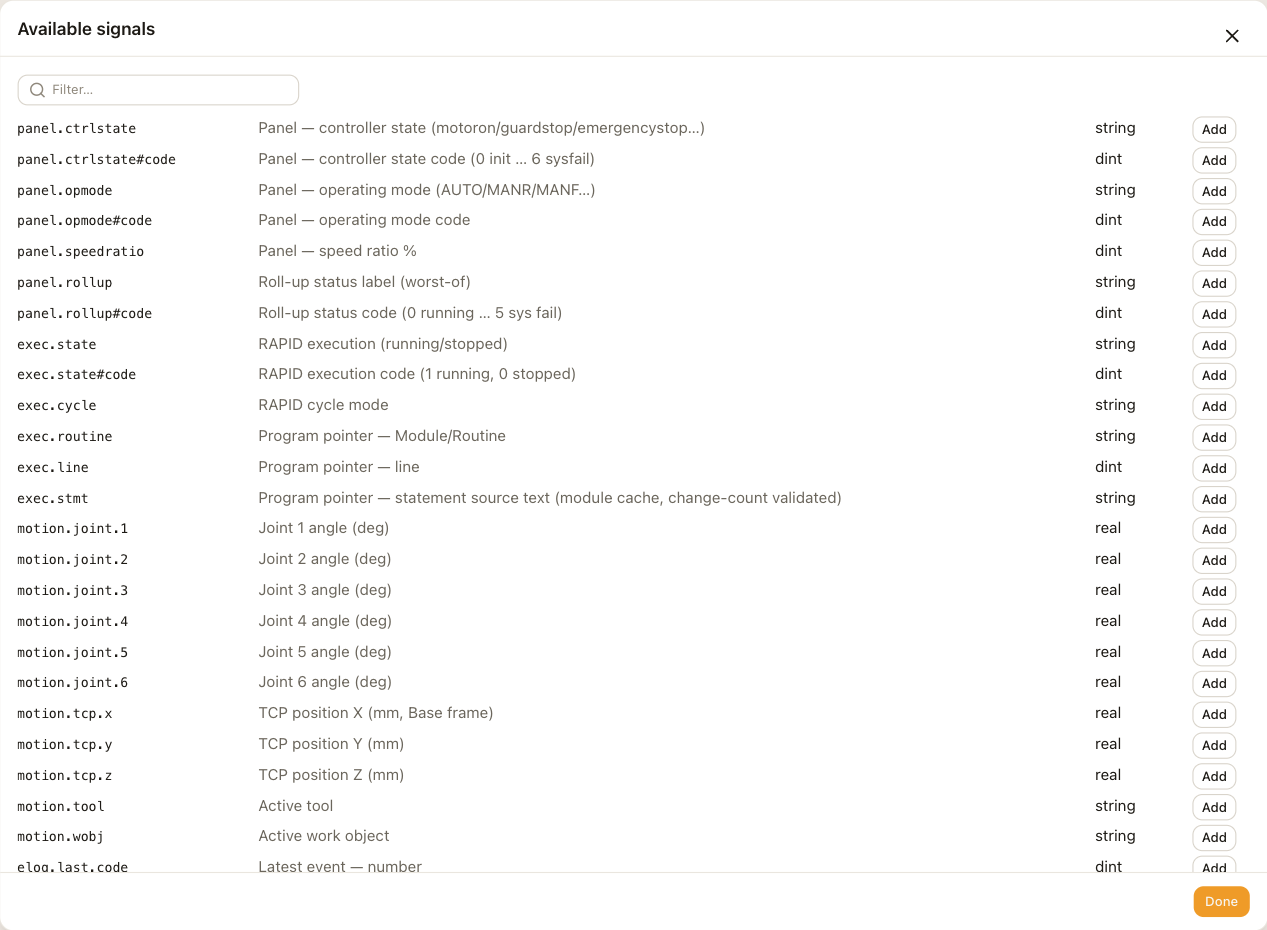
Open Tag library and choose Catalog next to the connection. The list shows the profile's catalog even while the robot is offline: the panel state, execution, motion, event and system addresses. When the robot answers, its I/O signals and RAPID symbols follow. Every address, its type and its state codes are on the profiles page.
Addresses by hand
Choose Add tag to read a signal that is not in the catalog. Each one costs one request per poll.
io:Network/Device/Signalreads an I/O signal. Two parts assume theLocalnetwork. For a bare name, the camera searches the controller.rapid:Task/Module/Symbolreads a RAPID persistent, variable or constant. A record or an array takes a component after#, such as#xor#2.
Polling
One poll makes one request per group of signals, and reads only the groups that a used tag needs. A panel needs the status and program groups, a figure adds the motion group, and tags you add need theirs. One second is the profile's default poll interval.
Limitations
- The connection reads one mechanical unit and one RAPID task, the first of each. A MultiMove controller shows its first robot.
- The connection keeps only the latest event of each poll. When a fault raises several entries in one second, the panel and the records show the last one.
Troubleshooting
The Connections row shows the reason for the last failure.
| Reason | Check |
|---|---|
| authentication failed (check username/password) | The username and password. The factory default is Default User and robotics. |
| robot unreachable | The host, and that the camera can reach the robot's network. |
| answered … but: HTTP 500 | Robot Web Services on the controller. It answered but did not serve the request. |
| RWS status … | The user's grants on the controller. A RobotWare 6 user needs read access to the resources the camera reads. |
| robot returned 503 (session limit) after retry | Other clients holding Robot Web Services sessions. Close them, or wait for their sessions to expire. |
| robot stopped answering (3 polls) | The robot went offline while connected. The roll-up reads OFFLINE, the panel shows NO LINK, and values keep their last reading with a !. |